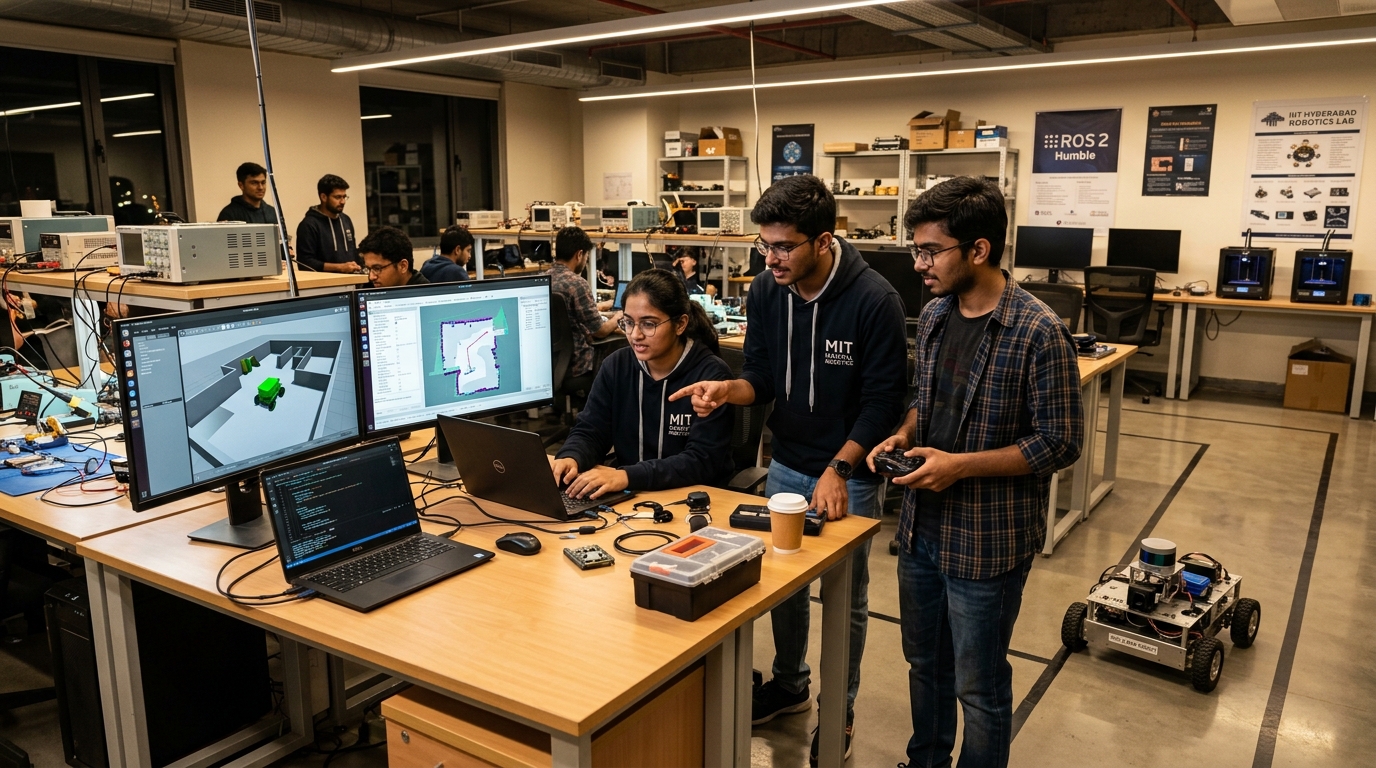
Training & Workshop on ROS Robotics
Training & Workshop on ROS Robotics
Key Highlights & Technical Capabilities
ROS 2 & Linux Architecture
Master nodes, topics, publishers, subscribers, services, and action servers on modern ROS 2 Humble/Iron distributions.
SLAM & Sensor Fusion
Real-time 2D/3D LiDAR sensor integration, depth cameras, IMU Kalman filtering, and Nav2 autonomous waypoint navigation.
Physical Robot Deployment
Direct hands-on programming on differential-drive and Mecanum mobile robot platforms with live arena challenges.
Program Overview
The AxiLearn ROS Robotics Training & Workshop is an industry-grade experiential program tailored for engineering colleges and research departments. Participants transition from core Linux robotics fundamentals to simulating complex robot kinematics in Gazebo, implementing SLAM (Simultaneous Localization and Mapping), and deploying autonomous navigation algorithms on physical mobile robotic platforms.
Curriculum & Module Roadmap
Linux for Robotics & ROS 2 Core Architecture
Linux CLI, ROS 2 workspace build system (Colcon), nodes, topics, message serialization, services, actions, and launch files.
URDF Robot Modeling & 3D Kinematics in Gazebo
Unified Robot Description Format (URDF/Xacro), TF2 transform trees, physics simulation setup in Gazebo, and actuator plugins.
Sensor Fusion: LiDAR, Depth Cameras & IMU
Interfacing 2D/3D LiDAR, Intel RealSense depth sensors, point cloud processing in PCL, and IMU orientation filtering.
SLAM Mapping & Autonomous Waypoint Navigation (Nav2)
Cartographer and SLAM Toolbox 2D/3D map generation, costmap layers, A*/Dijkstra global path planners, and DWB local controller.
Robotic Arm Kinematics & Manipulation with MoveIt 2
Forward and inverse kinematics, MoveIt 2 planning pipelines, collision avoidance, and pick-and-place gripper control.
Hardware Deployment, Testing & Mini-Hackathon
Porting algorithms to physical mobile robot hardware, arena trials, obstacle course races, and student performance evaluation.
Institutional & Student Deliverables
- Comprehensive hardware test kits and mobile robot platforms for lab training sessions.
- AxiLearn ROS 2 master certification with project GitHub code repository verification.
- Complete lecture slide decks, simulation code packages, Docker images, and step-by-step lab manuals.
- Faculty coordination and student mini-hackathon judging with awards and certificates of excellence.
Deploy This Program at Your Institution
Book an on-campus demonstration, request turnkey lab setup proposals, or customize syllabi for your department.
